MimicLite
Train SONIC-level humanoid motion tracking policies with 8 GPUs at ~1/500 of SONIC compute — a full pipeline across data, assets, training, teleoperation, and Sim2Real deployment.

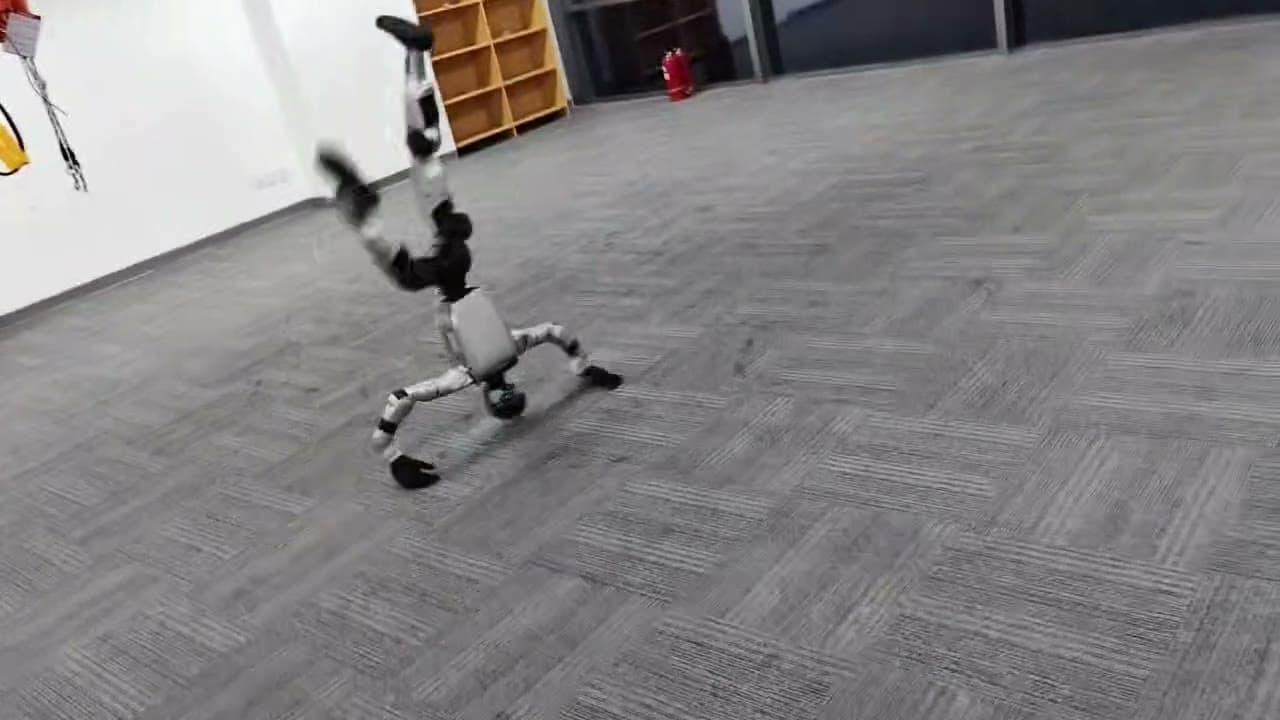
MimicLite is an open-source training and deployment infrastructure for general-purpose humanoid motion tracking. It uses 8 GPUs and roughly 1/500 of SONIC's training compute to produce SONIC-level tracking policies, with support for mjlab / IsaacLab, PPO / SAC, multi-dataset any4hdmi pipelines, mjhub asset management, 0.1-second low-latency Pico teleoperation, and 10-minute-level adaptation of any codebase policy to Sim2Real.
Fast & Scalable Training
MimicLite uses roughly 1/500 of SONIC's training compute. With 8 H200 GPUs and about two hours of training, it surpasses the SONIC policy on root-tracking metrics. The system supports mjlab and IsaacLab simulation backends, PPO and SAC reinforcement-learning algorithms, and further scaling with more environments, GPUs, and model capacity to continue improving high-dynamic motion completion and tracking accuracy at larger scale.
Motion Tracking Infra
MimicLite is a set of infrastructure organized around humanoid motion tracking. mjhub manages robot assets in a unified way, reducing asset maintenance cost and preventing inconsistency across training, forward-kinematics, and sim2sim validation stages. any4hdmi handles motion dataset conversion, processing, visualization, and loading — unifying datasets such as LAFAN, 100STYLE, SONIC, and Real into a storage-efficient HDMI format with automatic forward-kinematics caching. Multiple codebases connect through unified asset references, a unified motion format, and unified policy artifacts, eliminating repeated glue code for each dataset, robot, or training backend.
Low-latency Teleop
MimicLite supports roughly 0.1-second end-to-end Pico / XR teleoperation. Pico / XR inputs are converted into reference motions in real time, and the policy outputs low-level control targets that can be reused between MuJoCo and real robots. The current policy already supports continuous transitions on the real robot — turning, sidestepping, shuttle running, low-stance squatting, and kneeling recovery — while maintaining high root-tracking precision, making it suitable for real-time control, demo data collection, and downstream full-body task development.
Modular Sim2Real
The Sim2Real deployment side supports custom observation functions as policy inputs. An agent invokes the built-in adapt skill, traces external training code, implements the corresponding observation function, and generates a deploy YAML — connecting any codebase-trained policy into MimicLite's Sim2Real deployment path in about 10 minutes. Deployments for sonic, humanoid-gpt, twist2, and teleopit are already supported. This design lets MimicLite serve not only its own policies but also act as an adaptation layer for cross-codebase policy evaluation and real-robot deployment.