


Environmental Perception
Focus on perceiving complex real-world environments to provide a stable foundation for robot decision-making and continuous interaction.
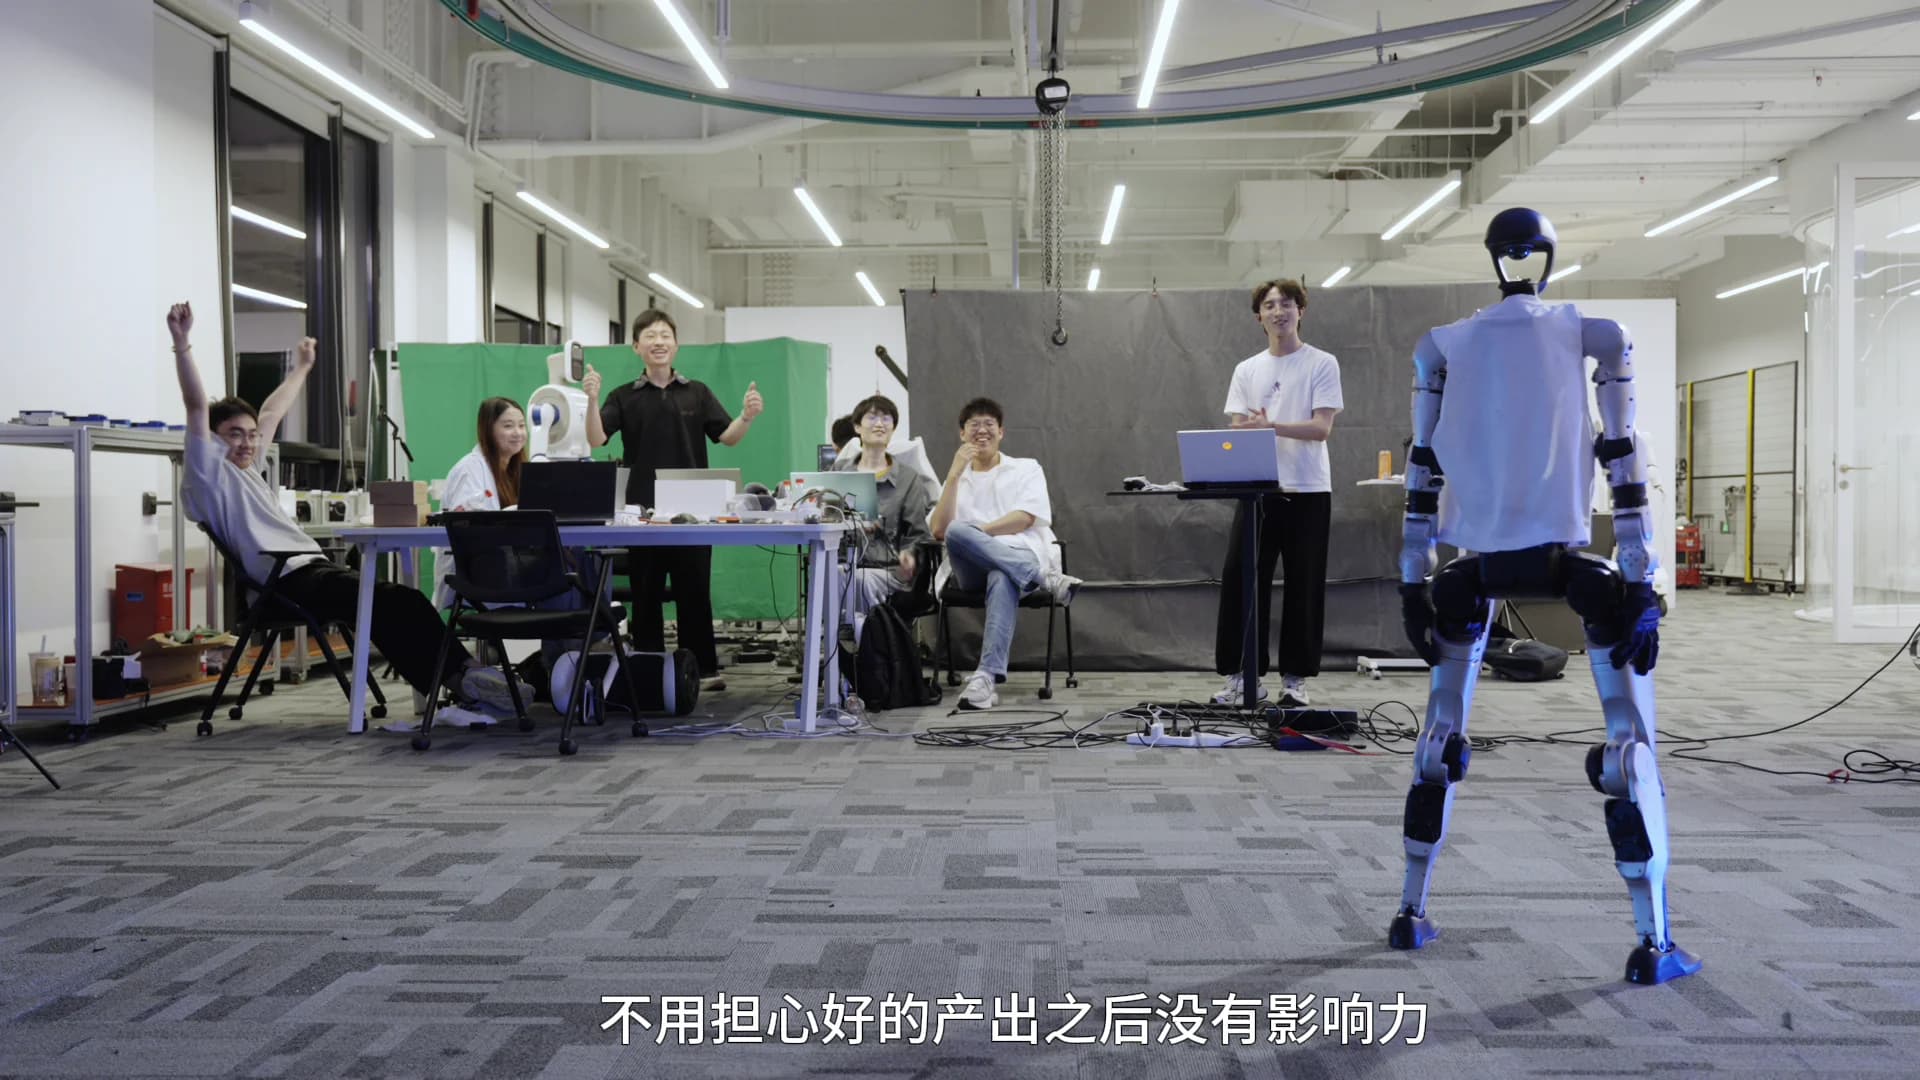
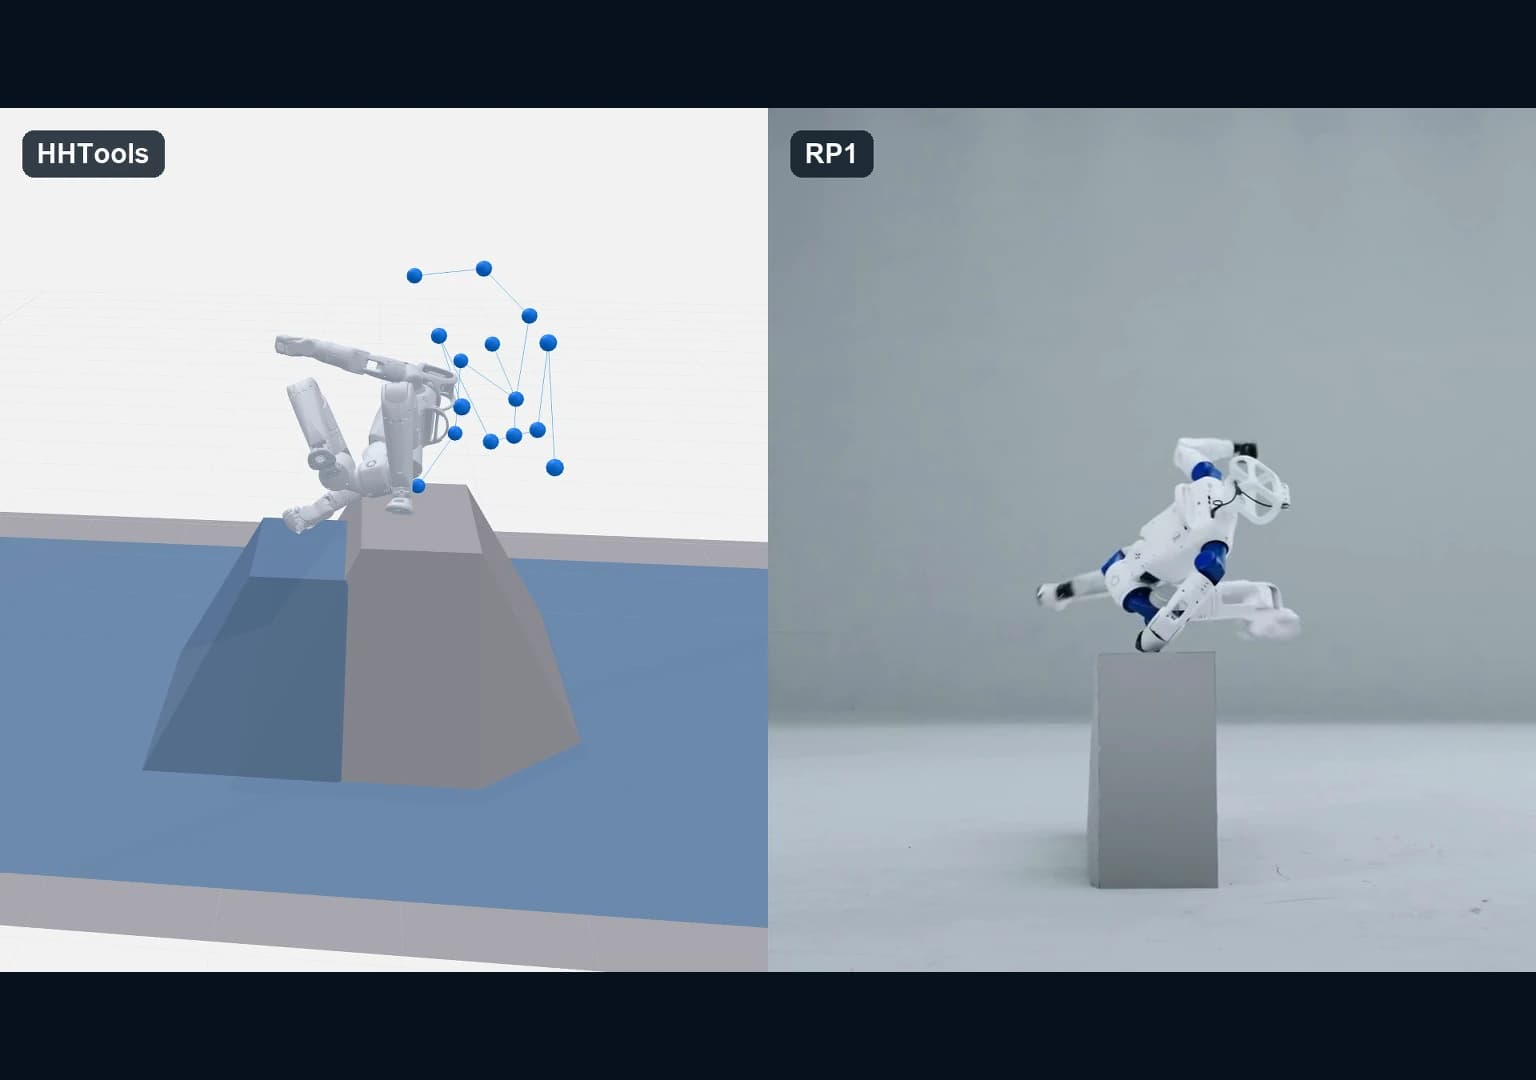
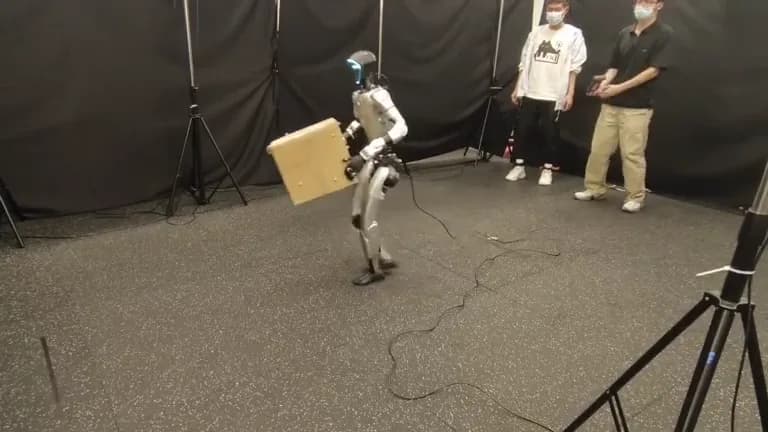
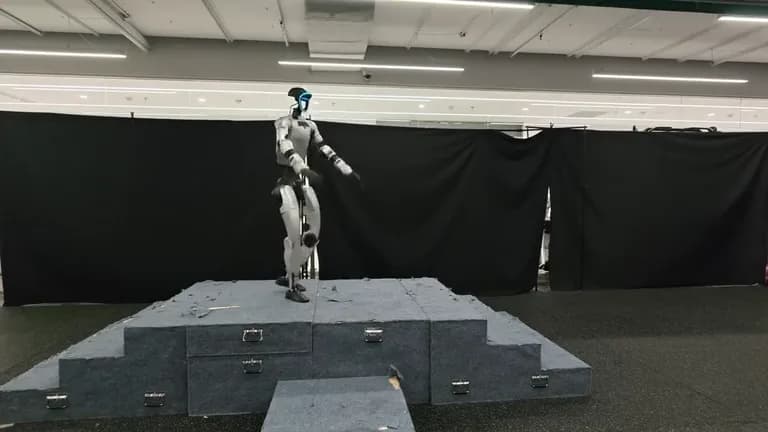
Build locomotion infrastructure spanning data generation, motion retargeting, training frameworks, Sim2Real / Real2Sim deployment, and Behavior Foundation Models (BFM) to advance robot motion capabilities and development efficiency.
Slide 1 of 6
Develop environmental perception, human–scene interaction (HSI), and human–object interaction (HOI) to strengthen perception, decision-making, and continuous interaction in complex real-world environments, laying a stable foundation for manipulation intelligence.
Slide 1 of 3
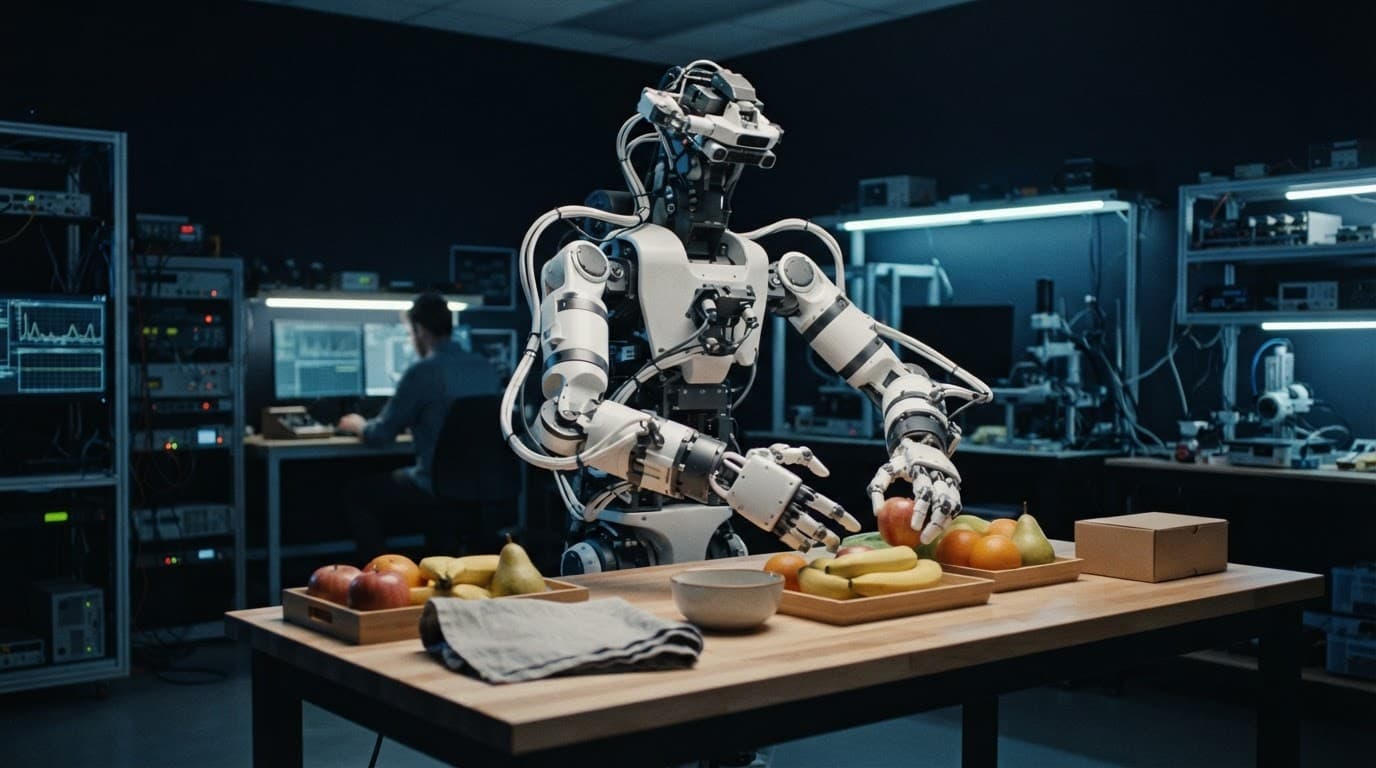
Bring together Behavior Foundation Models (BFM), vision-language-action models (VLA), and World Models to advance whole-body coordination and complex manipulation, building an infrastructure for manipulation intelligence that can generalize at scale.
Slide 1 of 3
Build on an Agent + Skills architecture to explore robot task planning, autonomous execution, and skill composition, advancing humanoid robots from single-task execution toward autonomous agents.
Slide 1 of 3
Agentic RSI System
Our mission is to empower high potential, early stage startups through Google's AI and Gemini Robotics models. We're helping transform their discoveries into market-leading ventures – and to power an era of intelligent physical AI.
Learn more
We welcome researchers, engineers, and open-source contributors who care about humanoid robotics. Explore locomotion, perception, and manipulation with us, turn ideas into capabilities on real robots, and share what we build with developers everywhere. Pursue the frontier. Stay true to what drives us.
Learn more